About Me
Hi, I’m Jiawei, a Ph.D. in Mechanical Engineering and a Medical Roboticist with over 8 years of experience advancing autonomy in robotic surgery. My work is dedicated to achieving higher levels of precision and efficiency, with a focus on autonomous robotic solutions for cancer surgery.
I work with Professor Axel Krieger in the IMERSE Lab, where we develop cutting-edge technologies to revolutionize robotic-assisted surgeries and improve patient outcomes.
Research
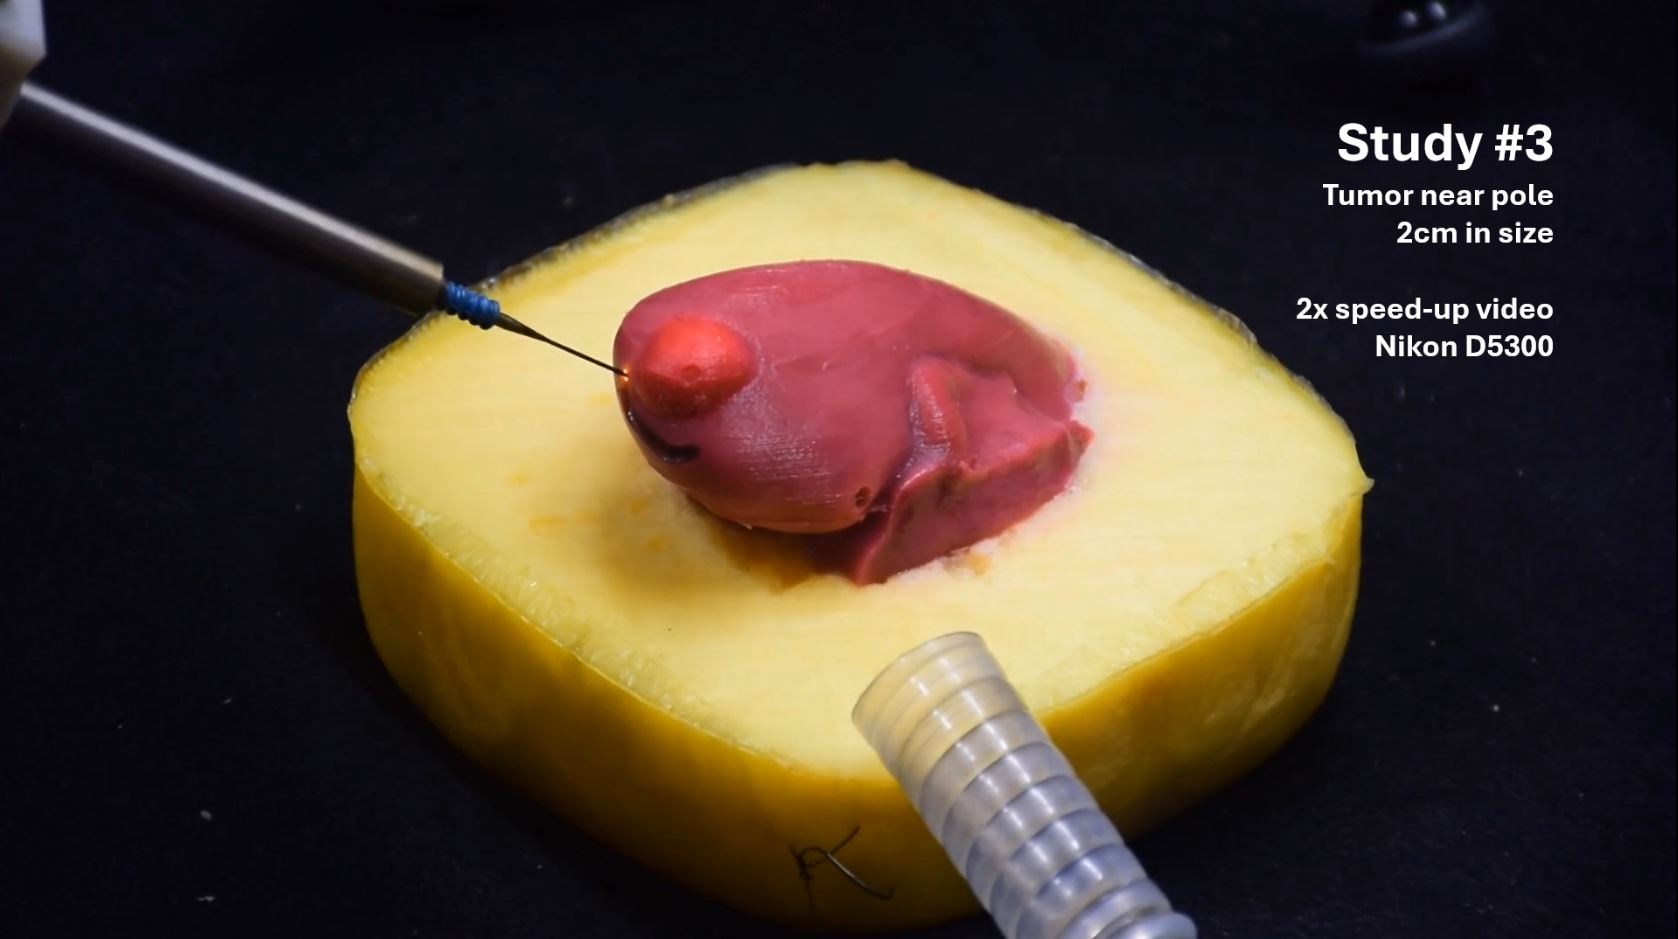
Ethan Kilmer†, Joseph Chen†, Jiawei Ge, Preksha Sarda, Richard Cha, Kevin Cleary, Lauren Shepard, Ahmed Ezzat Ghazi, Paul Maria Scheikl, and Axel Krieger.
Journal of Medical Robotics Research (JMRR), 2025.
We developed a fluorescence-guided autonomous robotic system, validated with novel hydrogel-based kidney phantoms, that enables precise resection of exophytic renal tumors with a clinically relevant margin accuracy of 1.44 mm in under 70 seconds.
Learn more on Video Submission for JMRR/ISMR 2025.
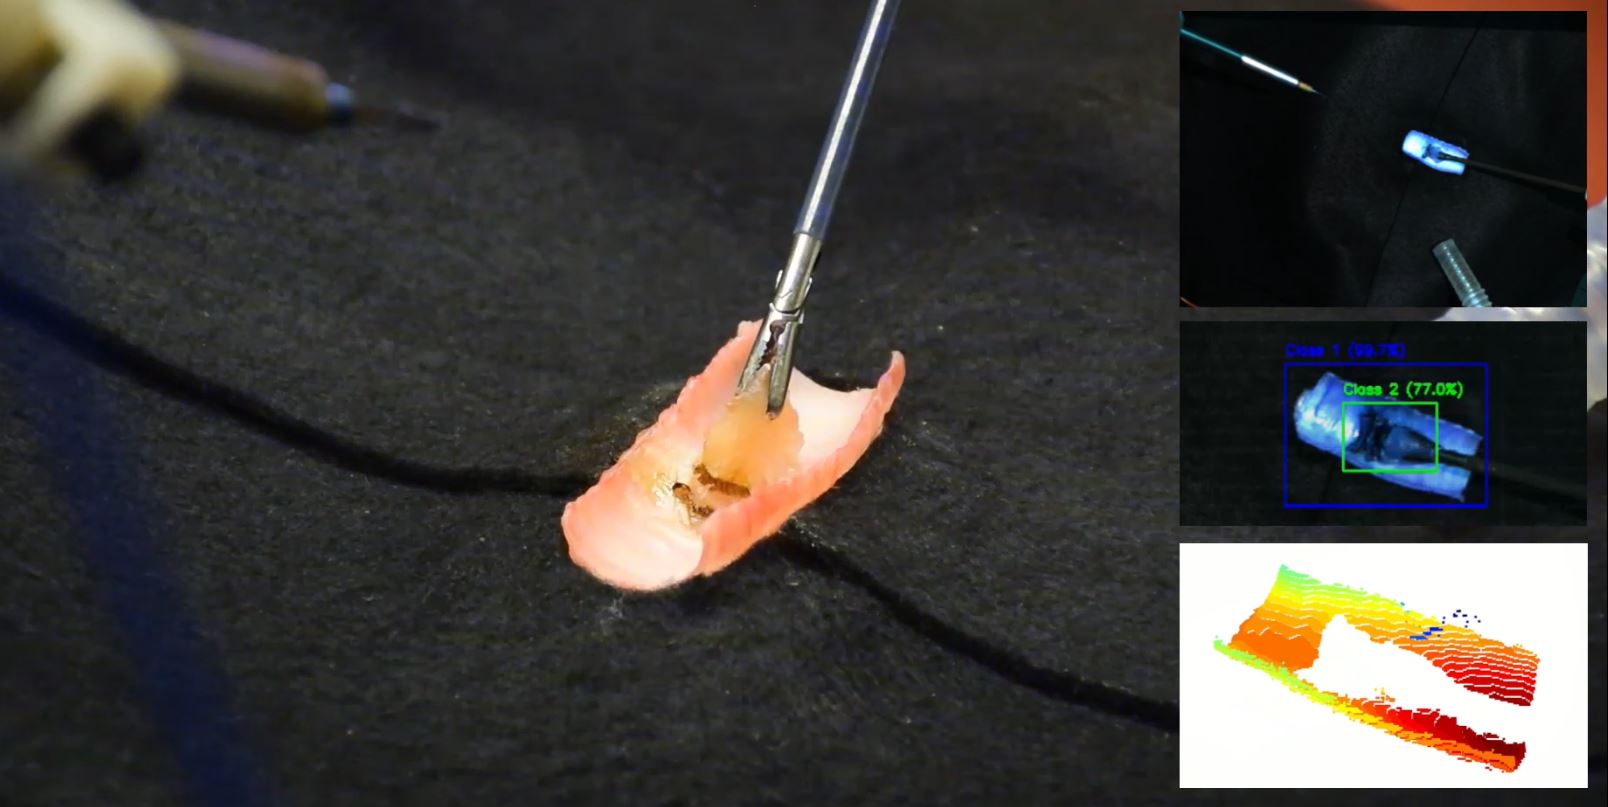
Autonomous Vision-Guided Resection of Central Airway Obstruction
Mariana E. Smith†, Nural Yilmaz†, Tanner Watts, Paul Maria Scheikl, Jiawei Ge, Anton Deguet, Alan Kuntz, and Axel Krieger.
Journal of Medical Robotics Research (JMRR), 2025.
We propose a vision-guided, autonomous robotic system for precise palliative tracheal tumor resection, achieving over 90% volumetric tumor removal while maintaining a 1mm safety clearance from the tracheal surface in ex-vivo validation experiments.
Learn more on Video Submission for JMRR/ISMR 2025.
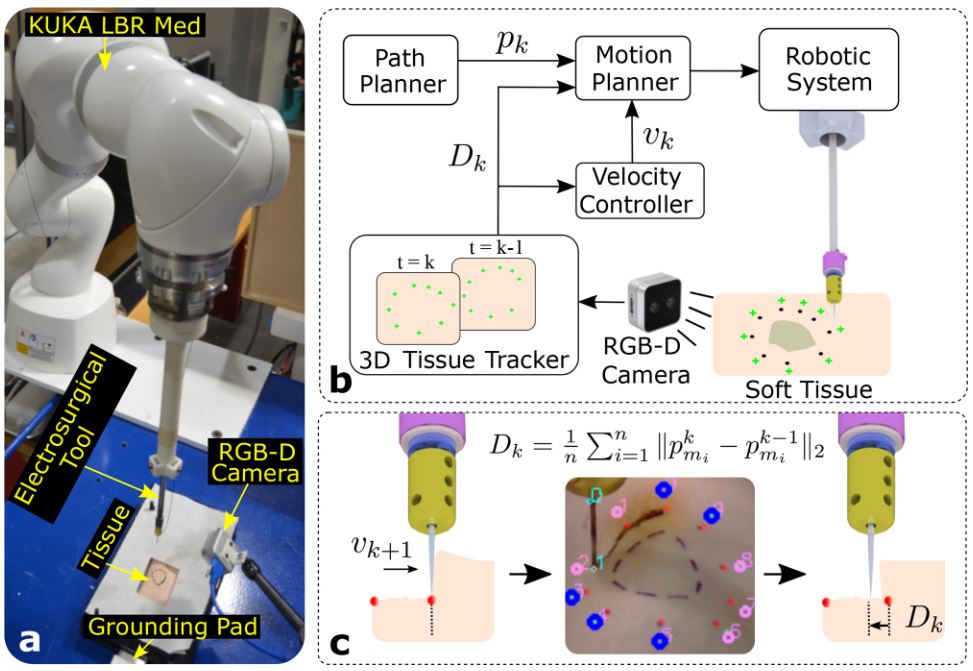
Autonomous Closed-Loop Control for Robotic Soft Tissue Electrosurgery Using RGB-D Image Guidance
Michael Kam, Jiawei Ge, Naveed D Riaziat, Justin D Opfermann, Leila J Mady, Jeremy D Brown, Axel Krieger.
IEEE Transactions on Medical Robotics and Bionics (T-MRB), 2025.
We present an autonomous closed-loop robotic electrosurgery system that leverages 3D tissue tracking and image-based feedback control to enhance margin accuracy, achieving a 55% reduction in cutting error during tumor excision in ex vivo porcine tongue validation experiments.
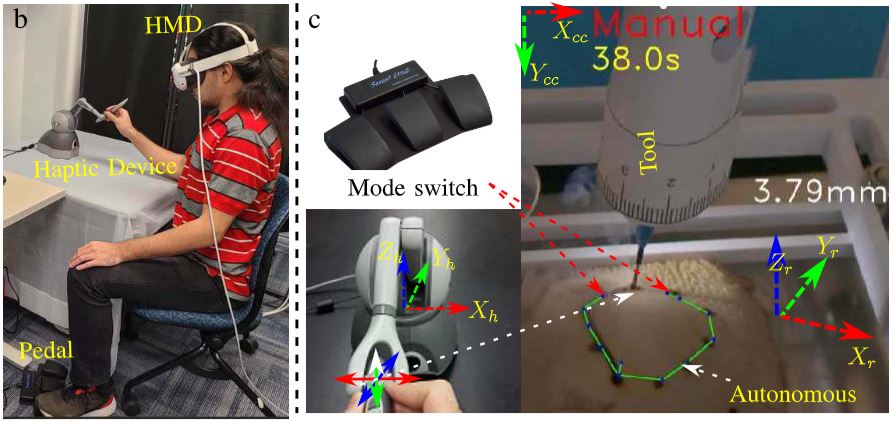
A Confidence-Based Shared Control Strategy for Robotic Electrosurgery
Artmeio Meza-Pantoja, Andrew C. Lawson, Charlie C. Caputo, Jiawei Ge, Dale J. Cohen, Axel Krieger, Hamed Saeidi.
IEEE Transactions on Medical Robotics and Bionics (T-MRB), 2025.
We developed a shared control strategy for robotic electrosurgery, combining autonomous precision with human intervention to achieve more accurate soft tissue incisions and reduce human-in-the-loop time by 69.29% in validation experiments on porcine tongue samples.
Learn more on Video Submission for TMRB 2025.
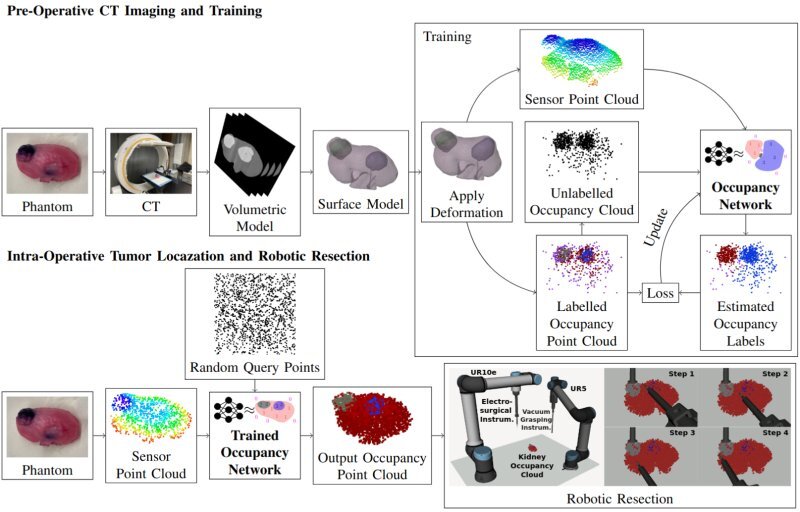
Tracking Tumors under Deformation from Partial Point Clouds using Occupancy Networks
Pit Henrich†, Jiawei Liu†, Jiawei Ge, Samuel Schmidgall, Lauren Shepard, Ahmed Ezzat Ghazi, Franziska Mathis-Ullrich, Axel Krieger.
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2024.
We developed an occupancy network-based approach for real-time tumor localization in deforming kidney phantoms during robot-assisted partial nephrectomy (RAPN), enabling accurate volumetric 3D tumor tracking at interactive speeds to enhance surgical precision.
Learn more on Oral Pitch Presentation video for IROS 2024.
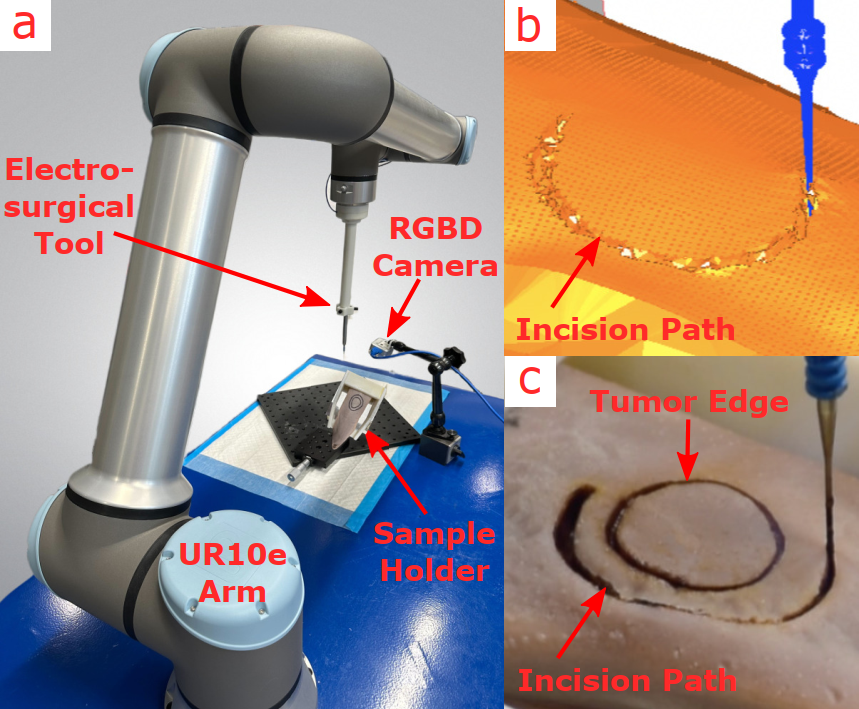
Jiawei Ge†, Ethan Kilmer†, Leila J Mady, Justin D Opfermann, Axel Krieger.
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2024.
Integrated physics-based cutting simulations with the Autonomous System for Tumor Resection (ASTR) to enhance precision in soft tissue tumor surgeries by preoperatively predicting and compensating for tool-tissue interaction deformations.
Learn more on Oral Pitch Presentation video for IROS 2024.
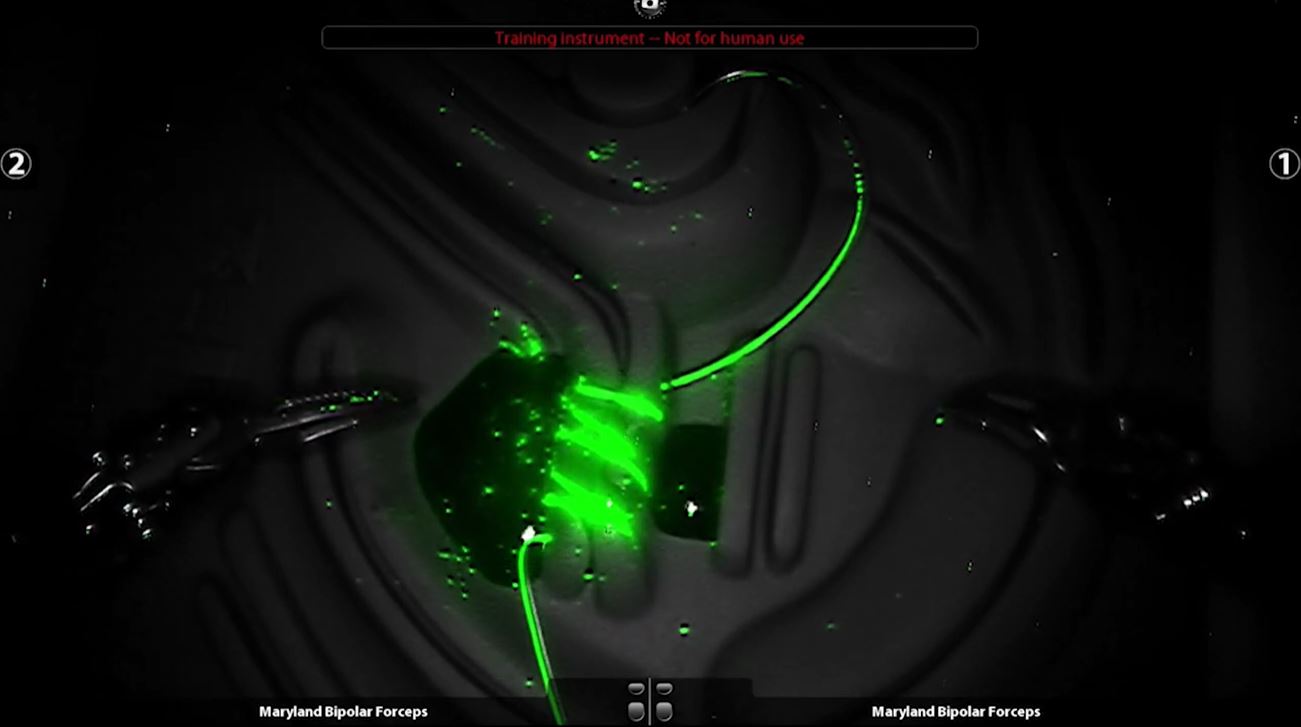
A Fluorescent Suture and Surgical Planner for Image Guided Surgery
Justin D. Opfermann, Jiawei Ge, Yaning Wang, Minjae Do, Jin U. Kang, and Axel Krieger.
Student Design Showcase, Design of Medical Devices Conference (DMD), 2024.
Glow and Sew suture is coated in fluorescent powder that glows under near-infrared light, which is also able to penetrate through the blood and tissue, allowing surgeons to always see where their stitches are.
Learn more on Johns Hopkins News.
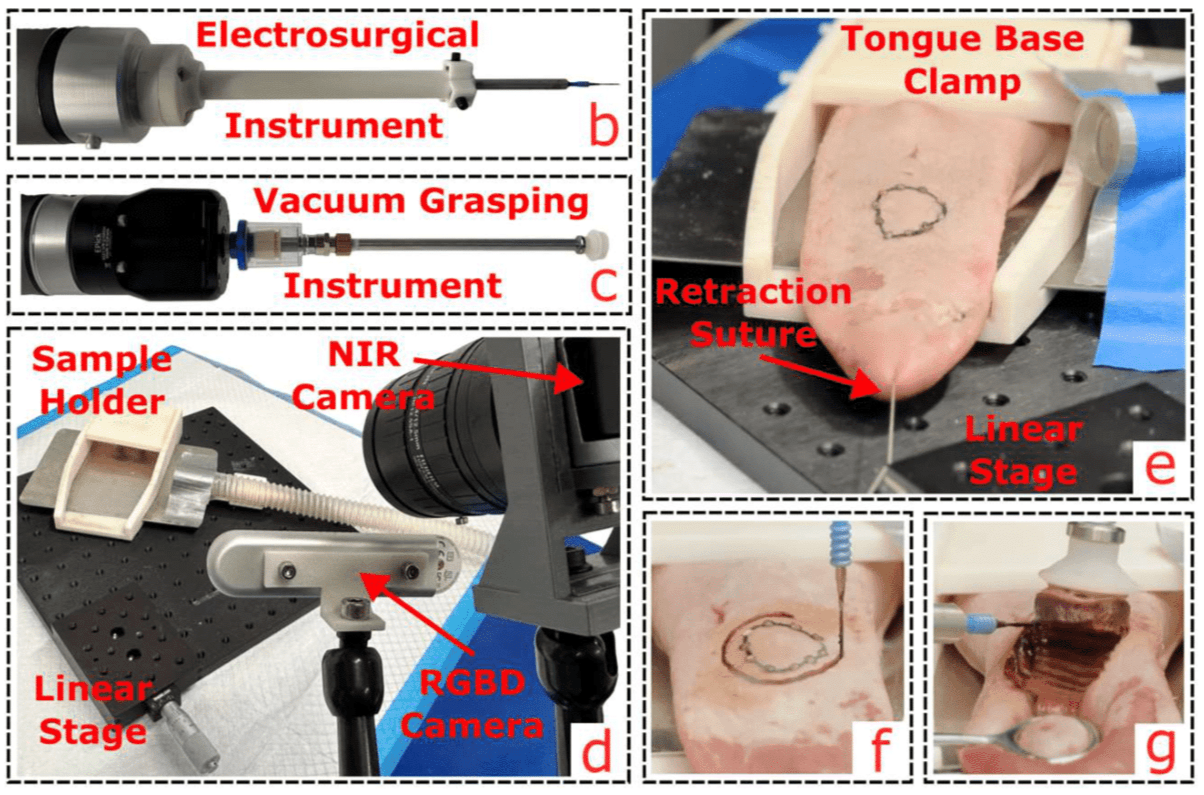
Autonomous System for Tumor Resection (ASTR) - Dual-Arm Robotic Midline Partial Glossectomy
Jiawei Ge, Michael Kam, Justin D. Opfermann, Hamed Saeidi, Simon Leonard, Leila J. Mady, Martin J. Schnermann, and Axel Krieger.
IEEE Robotics and Automation Letters (RA-L), 2024.
Introduced the development of the ASTR, a pioneering autonomous, dual-arm, vision-guided robotic system, specifically designed for the high-autonomy (level 4) surgical task of tumor resection.
Learn more on Johns Hopkins News or Oral Presentation video for ICRA 2024.
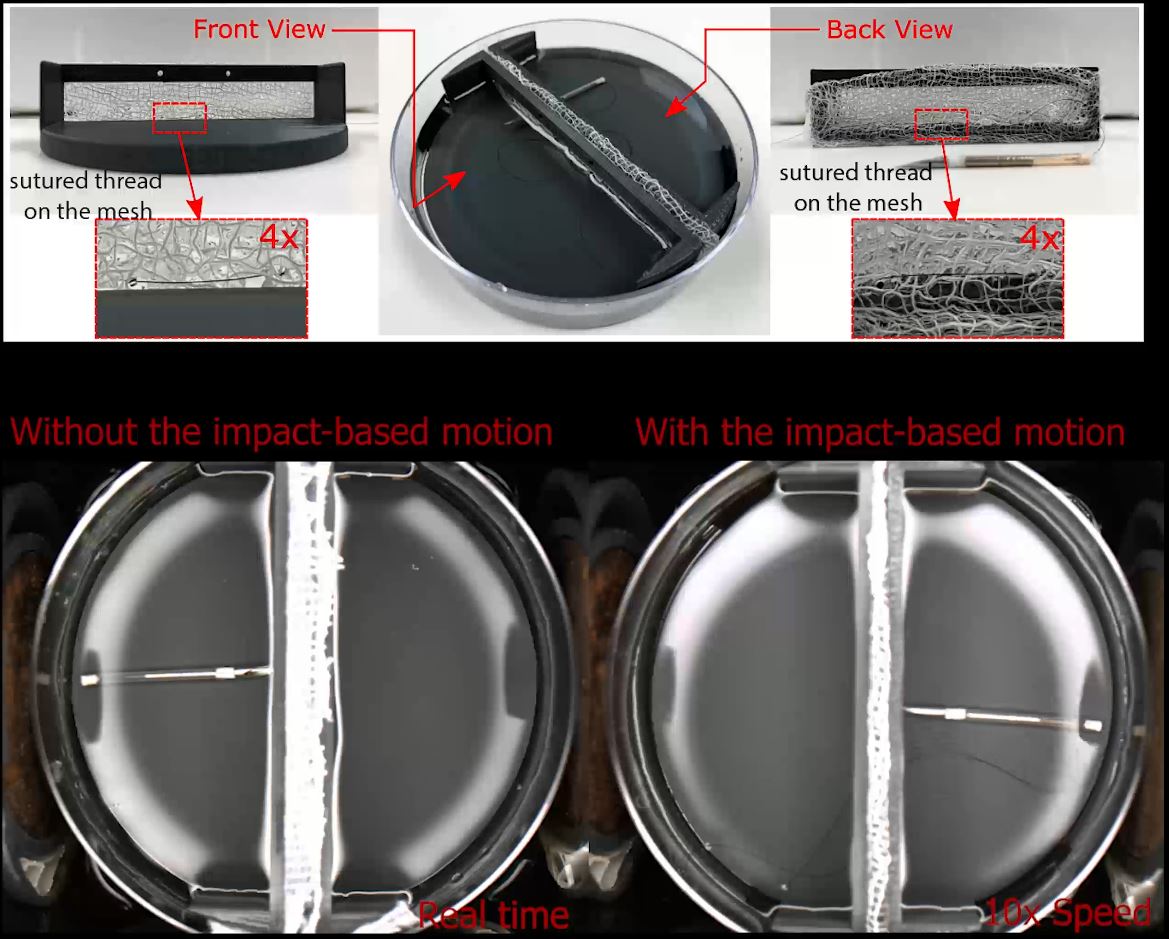
Onder Erin, Xiaolong Liu, Jiawei Ge, Justin Opfermann, Yotam Barnoy, Lamar O. Mair, Jin U. Kang, William Gensheimer, Irving N. Weinberg, Yancy Diaz-Mercado, and Axel Krieger.
Advanced Intelligent Systems (AIS), 2022.
We propose the MPACT-Needle, a magnetically actuated impact force-based suture needle that achieves a 22.7-fold increase in penetration force with a 20x smaller volume, enabling precise tissue penetration for ultraminimally invasive surgical tasks such as suturing, corneal injections, and transscleral drug delivery.
Learn more on Video submission part 1 and Video submission part 2 for AIS 2022.
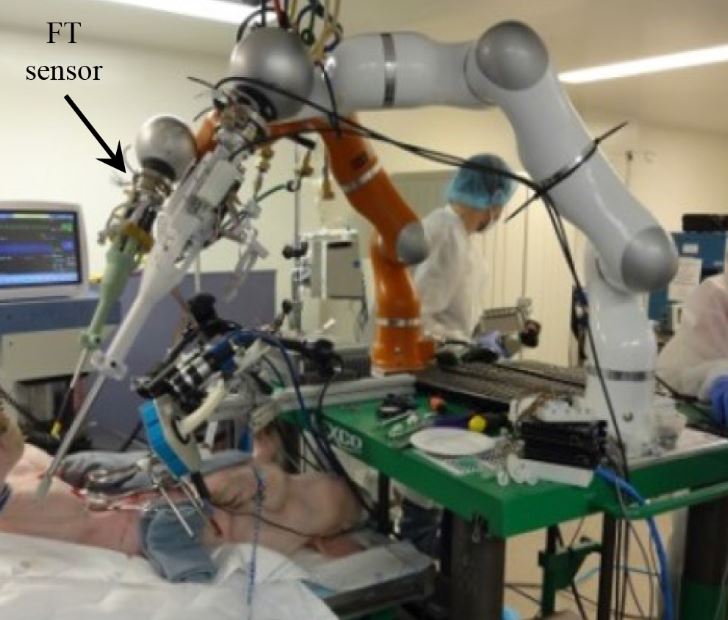
Vaginal Cuff Closure With Dual-Arm Robot and Near-Infrared Fluorescent Sutures
Simon Leonard, Justin Opfermann, Nicholas Uebele, Lydia Carroll, Ryan Walter, Christopher Bayne, Jiawei Ge, Axel Krieger.
IEEE Transactions on Medical Robotics and Bionics (T-MRB), 2021.
We present a dual-arm suturing robotic system that integrates novel near-infrared fluorescent sutures and automates thread management, achieving superior performance and consistency compared to human surgeons in ex-vivo and in-vivo vaginal cuff closure experiments.
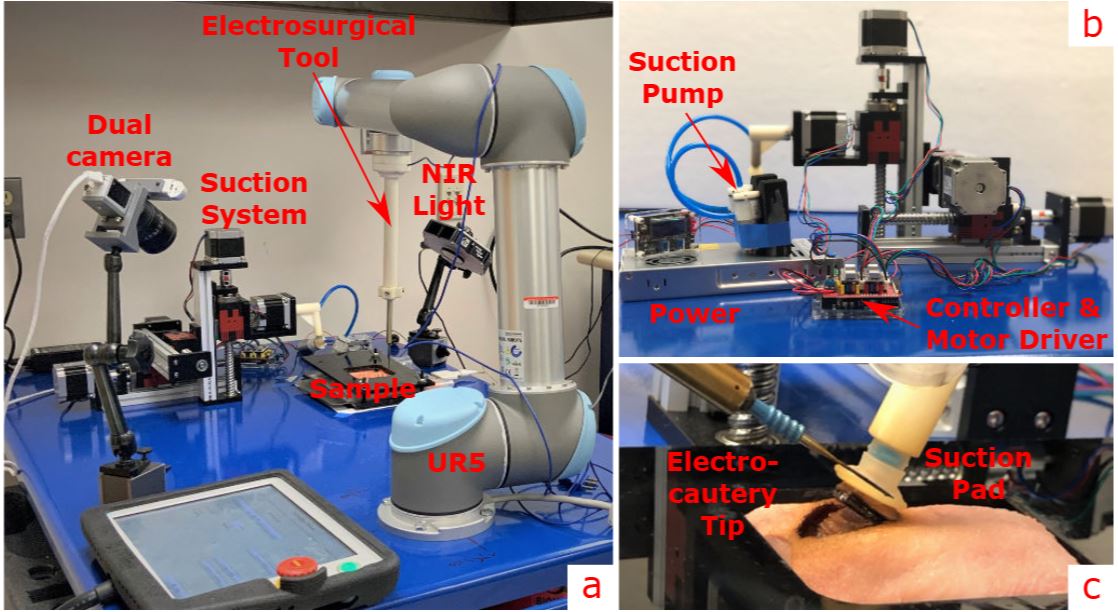
Supervised Autonomous Electrosurgery for Soft Tissue Resection
Jiawei Ge, Hamed Saeidi, Michael Kam, Justin Opfermann, Axel Krieger.
IEEE International Conference on Bioinformatics and Bioengineering (BIBE), 2021.
We present a robotic supervised autonomous electrosurgery system that integrates dual-camera NIR tracking and a dual-robot workflow, achieving precise soft tissue tumor resections with average surface and depth errors of 1.19 mm and 1.83 mm, respectively, in cadaveric porcine tongue experiments.
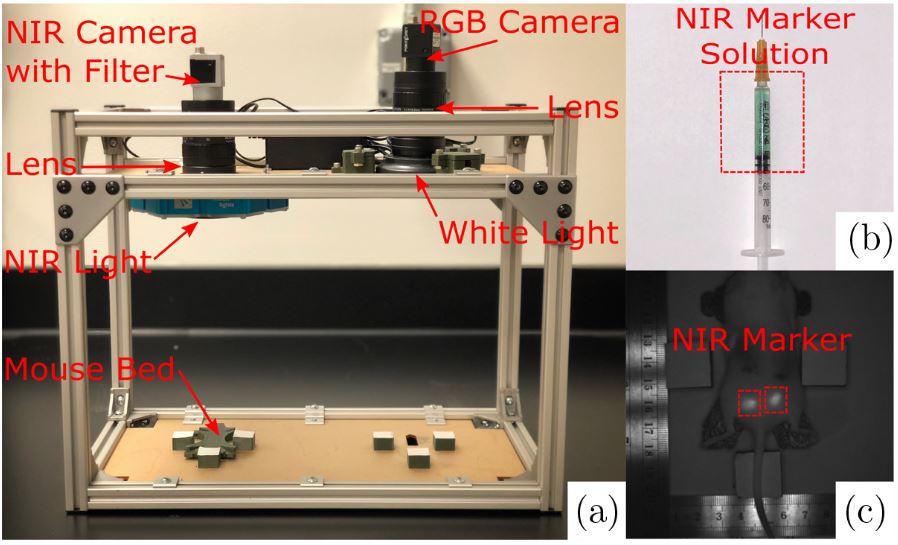
A Novel Indocyanine Green-Based Fluorescent Marker for Guiding Surgical Tumor Resection
Jiawei Ge, Justin D. Opfermann, Hamed Saeidi, Katherine A. Huenerberg, Christopher D. Badger, Jaepyeong Cha, Martin J. Schnermann, Arjun S. Joshi, and Axel Krieger.
Journal of Innovative Optical Health Sciences (JIOHS), 2021.
We introduce a novel near-infrared fluorescent marker that outperforms traditional India Ink in durability, visibility, and biocompatibility, maintaining consistent tumor localization and mapping during a six-week in vivo study and remaining visible even after electrosurgery.
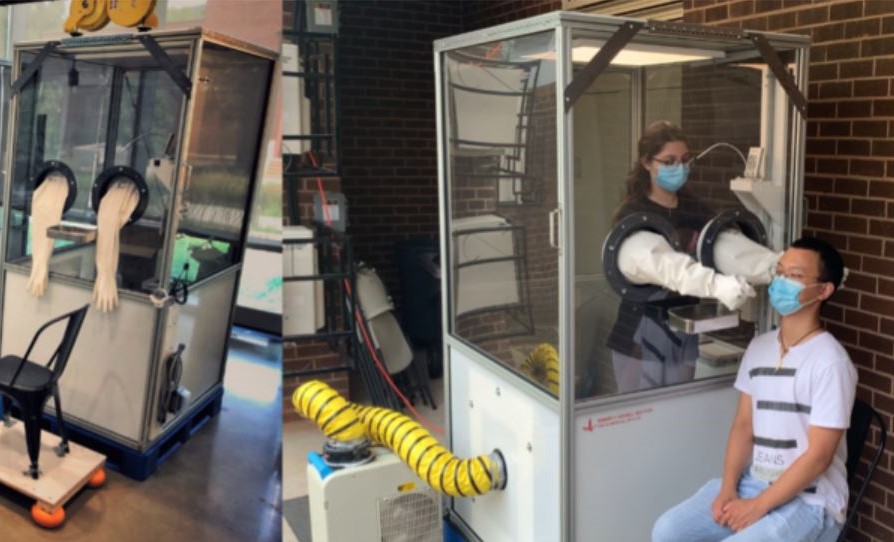
Positive Pressure Testing Booths Development and Deployment in Response to the COVID-19 Outbreak
Kevin Aroom, Jiawei Ge, Lidia Al-Zogbi, Marcee White, Adrienne Trustman, Adena Greenbaum, Jason Farley, Axel Krieger.
ASME Journal of Medical Devices (JMED), 2022.
We developed and deployed affordable positive-pressure COVID-19 testing booths, meeting CDC standards and enhancing accessibility, safety, and personal protective equipment conservation, with no reported health care provider infections across five units in Baltimore.
Learn more on Johns Hopkins News or CBS News.
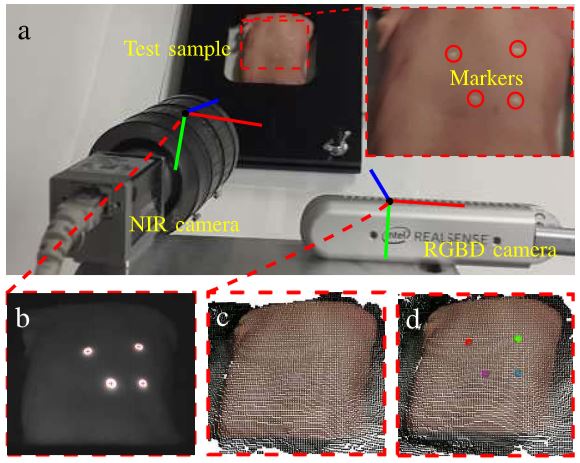
Supervised Autonomous Electrosurgery via Biocompatible Near-Infrared Tissue Tracking Techniques
Hamed Saeidi, Jiawei Ge, Michael Kam, Justin D. Opfermann, Simon Leonard, Arjun S. Joshi, and A Krieger.
IEEE Transactions on Medical Robotics and Bionics (T-MRB), 2019.
We developed a supervised autonomous 3D path planning and control strategy for the Smart Tissue Autonomous Robot (STAR), leveraging biocompatible NIR markers to achieve precise soft tissue incisions, reducing surface and depth errors by over 40% and 50% compared to teleoperation methods.
Learn more on Video Submission for TMRB 2019.
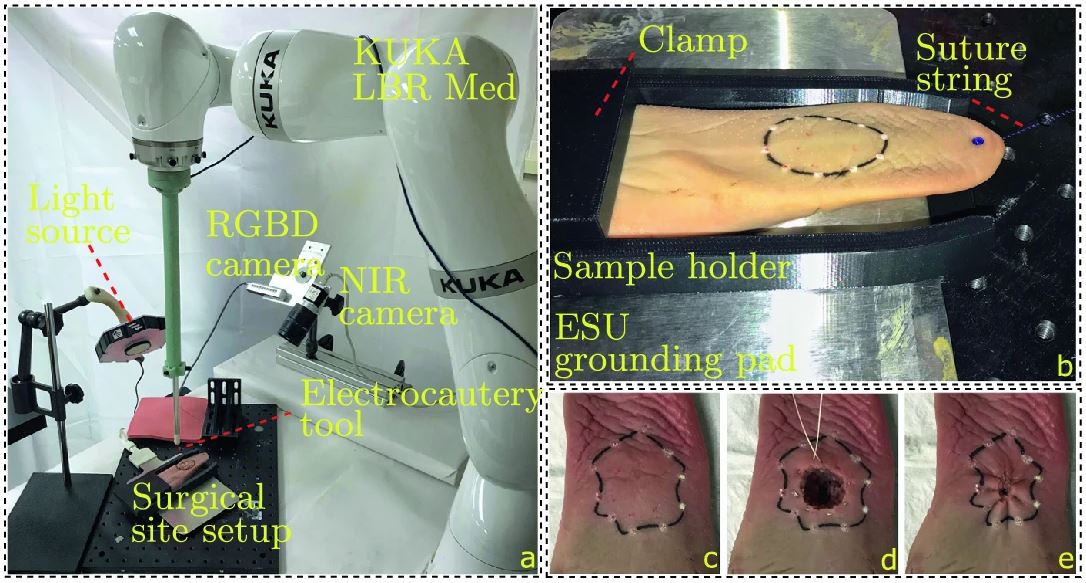
Landmark-Guided Deformable Image Registration for Supervised Autonomous Robotic Tumor Resection
Jiawei Ge, Hamed Saeidi, Justin D Opfermann, Arjun S Joshi, Axel Krieger.
International Conference on Medical Image Computing and Computer Assisted Intervention (MICCAI), 2019.
We present a novel NIR fluorescent marking and deformable image registration method integrated with a robotic system, enabling precise prediction and tracking of deformed tumor resection margins and facilitating supervised autonomous tumor bed resections in ex vivo porcine tongue experiments.
Education
Johns Hopkins University, Baltimore, MD, United States
Ph.D. Mechanical Engineering
2017 - 2024
Columbia University, New York, NY, United States
M.S. Mechanical Engineering
2015 - 2017
Huazhong University of Science and Technology (HUST), Wuhan, Hubei, China
B.E. Mechanical Engineering
2011 - 2015
Ph.D. Thesis
Advances in Medical Image Guided Autonomous Robotic Tumor Resection
Advisor: Dr. Axel Krieger
https://jscholarship.library.jhu.edu/items/be00cd4a-d801-41e9-83b1-b6a3e17bf0c8